Goals
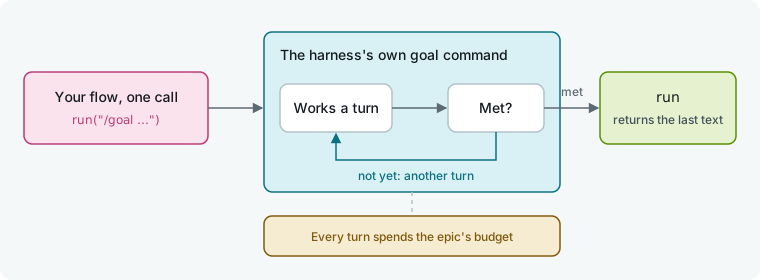
A goal is an objective you hand to an agent in place of a prompt. The agent works turn after turn until it judges the objective met. Your flow makes one run call and waits.
Set a goal from a flow
To set a goal:
- Add
GoalCommandAgentMixinto the role's type. - Start the
runprompt with/goal, followed by the objective.
# .hmz/flows/aim/__init__.py
from hmz.flows import (
    Agent,
    AgentCollection,
    EnvCollection,
    FlowContext,
    FlowParams,
    GoalCommandAgentMixin,
    LocalEnv,
    flow,
)


class Worker(Agent, GoalCommandAgentMixin): ...


class Agents(AgentCollection):
    worker: Worker


class Envs(EnvCollection):
    workspace: LocalEnv


@flow(agents=Agents, envs=Envs, params=FlowParams)
async def aim(
    task: str, *, agents: Agents, envs: Envs, params: FlowParams, ctx: FlowContext
) -> str:
    """The task, set once as the agent's own goal."""
    worker = agents["worker"]
    session = await worker.spawn()
    return await worker.run(f"/goal {task}", session=session, env=envs["workspace"])
Humanize passes the objective to the harness's native goal command instead of sending /goal to the model as text. The harness runs for as many turns as it needs, and run returns the agent's last message when the goal is met.
The mixin has no methods. It declares that the role may send /goal, so only a harness with a goal command can fill it.
To run a goal without writing a flow, install the official goal flow from the catalogue.
Run the flow
Write an objective the agent can verify for itself.
In the app
Start the flow from New epic (see Flows), then open the epic and select the worker's session. The thread shows the /goal prompt from the flow, everything the agent did, and where it stopped.
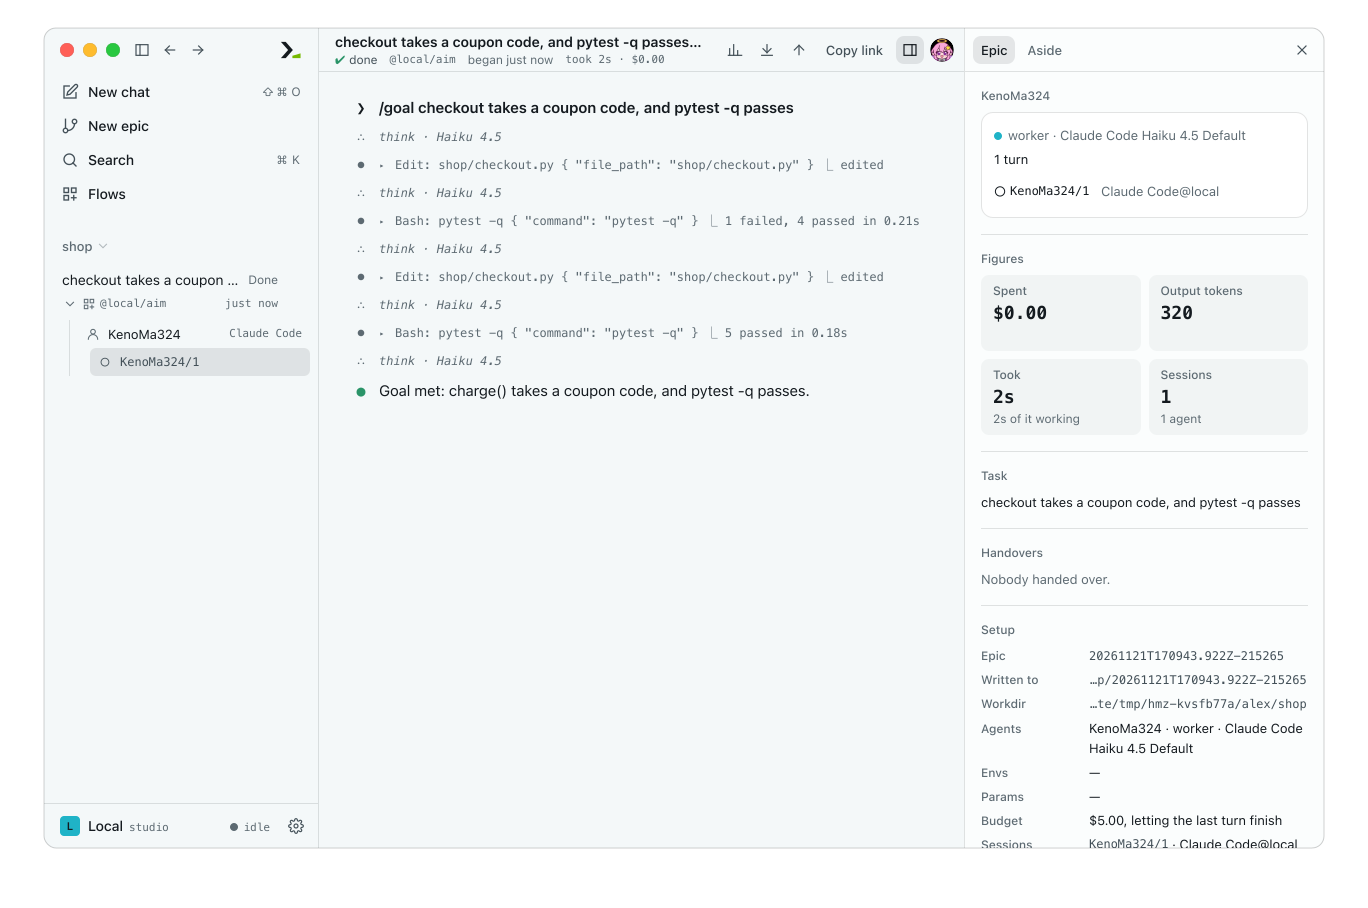
One prompt and one turn for the flow, however long the agent worked.
From the command line
hmz exec -f @local/aim -a worker=claude/claude-haiku-4-5 \
    -p budget.output_tokens=20000 \
    "checkout takes a coupon code, and pytest -q passes"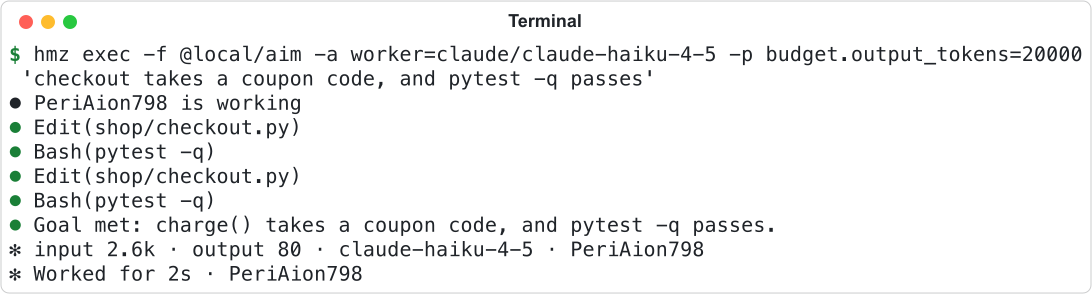
Check harness support
Harness (-a) | /goal | /loop |
|---|---|---|
claude | yes | yes |
codex | yes | no |
kimi | yes | no |
dsh | yes | no |
acp, agy, cursor-agent, grok, litellm, mcode, mimo, omp, opencode, pi, qwen | no | no |
A harness without the command cannot fill a role that declares the mixin. hmz exec refuses before the epic starts:
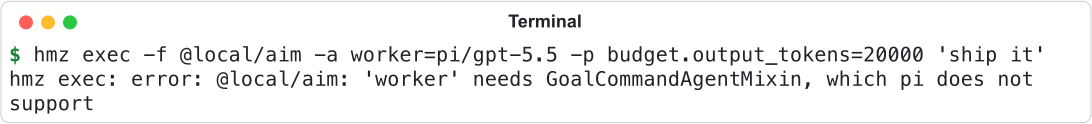
In the terminal, the role picker lists only compatible harnesses. In Python, this raises CapabilityMissing.
See Agents and harnesses for full harness capabilities, and Agent roles for declaring roles and mixins.
Repeat a task with /loop
Declare LoopCommandAgentMixin on a role to use /loop <interval> <task>, the harness's recurring task command. Only claude supports it. Humanize passes the prompt to the harness unchanged.
class Watcher(Agent, LoopCommandAgentMixin): ...


class Agents(AgentCollection):
watcher: Watcherawait watcher.run("/loop 10m check CI", session=session, env=envs["workspace"])Import LoopCommandAgentMixin from hmz.flows. To control a loop from your flow instead, write it in Python (see Loops).
Choose who decides the work is done
| Way | Who decides | Works on |
|---|---|---|
/goal | The agent, against the objective | claude, codex, kimi, dsh |
| A stop hook that blocks | Your code, each time a turn is about to end | Every harness |
| A loop in the flow | Your code, between turns | Every harness |
See Hooks for stop hooks.
Test the flow
A fake agent emulates claude by default, or any harness you name, with that harness's exact capabilities. Use it to test both the prompt and the refusal (see Test a flow).
# tests/test_aim.py
import pytest

from hmz.flows import CapabilityMissing
from hmz.sdk import fakes


async def test_the_task_becomes_a_goal() -> None:
    worker = fakes.FakeAgentDriver()

    await fakes.run_fake("aim", "ship it", agents={"worker": worker})

    assert worker.prompts == ["/goal ship it"]


async def test_a_harness_without_goals_is_refused() -> None:
    pi = fakes.FakeAgentDriver("pi")

    with pytest.raises(CapabilityMissing):
        await fakes.run_fake("aim", "ship it", agents={"worker": pi})
Good to know
- A role without the mixin cannot send the command, even on
claude.runraisesCapabilityNotGrantedbefore sending:worker: /goal needs GoalCommandAgentMixin on the role. The same applies to/loopwithoutLoopCommandAgentMixin. - Start the prompt with exactly
/goaland one space, with nothing before it. Only that form sets the harness's goal; a prompt with whitespace before/goal, or with a tab or newline after it, reaches the harness as ordinary text. - The role needs the mixin whenever the prompt, after leading whitespace, is
/goalalone or/goalfollowed by whitespace./goalsis an ordinary prompt. - Humanize interprets no other slash command and passes every other prompt to the harness unchanged.
- Every turn of a goal spends the epic's budget. Set a budget to stop a goal that never settles (see Budgets in a flow).
- Vague objectives like "Make it better" never settle. Give the agent a condition it can check.
- A stop hook still runs when the goal ends. If it blocks, the turn continues with the hook's reason as an ordinary prompt, not as a new goal.
- A goal does not hold the harness to an
output_schema. Humanize only reads the last message as that model, and raisesOutputSchemaErrorif it is not one, so ask for the JSON in the objective. - Call
runwith/goalagain to set a fresh goal in the same session.